Search News
Global Industrial Intelligence Hub (GIIH)Industry Portal
Global Industrial Intelligence Hub (GIIH)Status
Standard Access
Upgrade to PremiumNewsHow AI delivery optimization adapts routes to real-time traffic
Time
Click Count
How AI delivery optimization adapts routes to real-time traffic
A traffic incident can turn an efficient delivery plan into a cascade of missed time windows. AI delivery optimization helps fleets respond by combining live traffic feeds, vehicle telemetry, and predictive travel-time models to reassess routes as conditions change. The critical question is not simply whether a system can reroute vehicles, but how reliably it balances traffic updates with delivery commitments, vehicle constraints, and operational costs.
That distinction matters because a navigation app and a fleet optimization platform solve different problems. One finds a suitable path to the next destination. The other must protect an entire delivery schedule while deciding which changes drivers and dispatchers can realistically execute.
Traffic changes the plan, not just the road
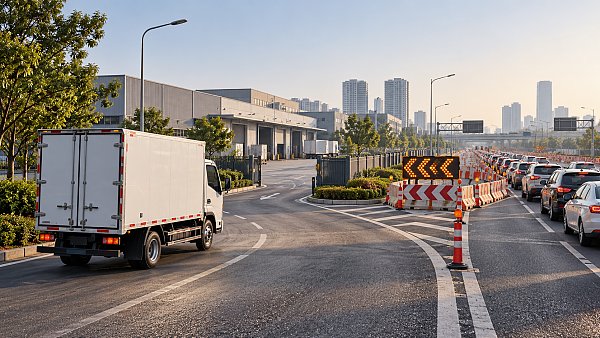
Consider a hypothetical delivery vehicle approaching a blocked arterial road. A detour may restore progress toward its next stop, yet still leave it too late for a receiving dock appointment. Visiting another customer first could work—but only if that customer is open, the shipment is accessible, and the revised sequence does not violate another commitment.
Dynamic routing therefore has several levels. A system can change the path between two stops, reorder the remaining stops, or reassign work across vehicles. These are not interchangeable capabilities. Reassignment may require a depot return or an authorized transfer point; software cannot assume that cargo moves between vehicles just because a revised schedule looks better.
Technical evaluations should establish exactly which decisions the platform supports during execution. “Real-time routing” sometimes means nothing more than refreshing estimated arrival times without changing the delivery plan.
From live signals to a defensible route update
A practical architecture separates data ingestion, travel-time prediction, constraint optimization, and dispatch. Machine learning often contributes to predicting travel times or stop durations, while mathematical optimization or heuristic search selects a feasible plan. The presence of AI does not eliminate the need for explicit operational rules.
Build a reliable picture of current conditions
Traffic inputs may include observed road speeds, incident reports, closures, and historical congestion patterns. Vehicle telemetry adds location, heading, and movement status. Order and dispatch systems supply completed stops, remaining loads, customer changes, and delivery restrictions.
These signals arrive at different speeds and with different confidence levels. A recent GPS message does not prove that the underlying traffic feed is fresh. Each observation needs a timestamp, source identity, and rules for handling stale or conflicting information. Map matching must also distinguish a vehicle on a main road from one on a nearby service lane; an incorrect match can trigger an unnecessary detour.
Predict conditions when the vehicle will arrive
Current speed alone is insufficient for a road segment the vehicle will reach later. Time-dependent travel-time models estimate conditions at the expected traversal time, using available traffic observations and historical patterns. Prediction quality usually becomes more uncertain farther into the route.
Arrival forecasts must also account for service time. Security checks, unloading, parking searches, and proof-of-delivery procedures can undermine an otherwise accurate driving-time estimate. These components should be measurable separately, so teams do not try to solve a loading-dock delay by changing the traffic model.
Reoptimize the remaining feasible work
The optimizer evaluates remaining work against updated travel times. This is commonly modeled as a dynamic, time-dependent vehicle routing problem with time windows and additional constraints. Because large problems may not be solved to proven optimality within an operational deadline, evaluators should ask about runtime limits, feasible fallback plans, and how solution quality is reported.
A rolling planning horizon allows repeated updates as new information arrives. Completed work stays fixed, while near-term commitments may be temporarily locked to avoid disrupting a driver already approaching a turn or customer entrance.
Why the fastest alternative may be the wrong choice
The optimization objective determines what “better” means. Minimizing driving time alone can produce unacceptable results when deliveries have different service priorities or vehicles face different restrictions.
Hard constraints exclude invalid plans: vehicle height limits, payload capacity, legally required breaks, or a delivery window that cannot be renegotiated. Soft constraints allow trade-offs, such as accepting limited lateness at a flexible stop to protect a critical appointment. Whether a requirement is hard or soft must come from the operation, not a vendor’s default configuration.
The objective may combine travel cost, overtime, lateness penalties, undelivered orders, and the disruption caused by changing an accepted plan. Ask how these terms are scaled. A low numerical penalty for lateness can quietly encourage missed commitments even when the dashboard reports lower mileage.
Sector differences matter here. A medical shipment may have handling and custody restrictions. Automotive parts deliveries may depend on production schedules or workshop bookings. Electric delivery vehicles need energy feasibility checks that consider route conditions, available charge, and charging access—not simply the shortest distance.
Responsiveness needs limits
Recalculating after every traffic fluctuation can create route churn: repeated changes that save little time while confusing drivers and dispatchers. Stable systems distinguish meaningful disruption from ordinary measurement noise.
Common controls include minimum improvement thresholds, a short commitment horizon, and limits on how often stop sequences may change. These settings require local testing. A dense urban operation and a long-distance distribution fleet should not automatically share the same trigger policy. Confirmed closures may also need to bypass ordinary thresholds.
There is an important exception: when no feasible route can preserve every commitment, the system should report that clearly. Returning an apparently valid plan by silently relaxing a hard constraint is not adaptation. It is a hidden operational failure.
Integration and standards: where evaluations get practical
Traffic-provider coverage deserves scrutiny at the delivery-road level. Strong highway coverage does not guarantee reliable information around industrial estates, private access roads, or loading entrances. Truck restrictions and temporary access rules may require separate map attributes or maintained local data.
Where relevant, DATEX II can support structured road-traffic information exchange, particularly in European deployments. It is not a certification of routing performance, nor does it guarantee complete local coverage. Confirm the interface, version, geographic scope, and licensing terms actually supported by each supplier.
There is no single universal “AI routing standard” that proves operational suitability. Procurement specifications need explicit acceptance criteria alongside applicable privacy, cybersecurity, road-use, and working-time requirements for each deployment market.
- State synchronization: Use consistent identifiers and versioned route updates so a delayed message cannot overwrite a newer plan.
- Delivery confirmation: Distinguish an update being transmitted, received, accepted, and applied by the driver application.
- Security and privacy: Define access permissions, encryption, location-data retention, and restrictions on secondary use.
- Degraded operation: Specify what remains available during traffic-feed, network, or optimization-service outages, and how known closures remain enforced.
End-to-end latency is more useful than solver speed alone. Measure the interval from an actionable event becoming available to a valid update reaching the vehicle. Data queues, travel-time matrix generation, approval workflows, and mobile connectivity can dominate that interval.
Test performance without hiding the difficult days
A credible evaluation starts with a baseline: the existing dispatch process or a simpler traffic-aware routing method. Compare operations with similar delivery density, vehicle types, service commitments, and demand patterns. Otherwise, a quieter operating period can look like an optimization improvement.
Historical replay is useful only if it respects what was knowable at each decision point. Feeding the model later incident information during an earlier routing decision creates data leakage. Likewise, historical driving records cannot directly prove how an untraveled alternative would have performed; counterfactual route outcomes require simulation assumptions and eventual field validation.
Use a small set of complementary measures rather than one headline saving:
- ETA quality: Absolute error, systematic early or late bias, and tail errors by prediction horizon and operating area.
- Service reliability: On-time delivery rate and lateness severity, separated by commitment type.
- Operational cost: Distance, paid hours, overtime, and failed deliveries under comparable workloads.
- Decision stability: Route changes per vehicle, dispatcher overrides, and driver acceptance.
- System reliability: Feasible-plan availability, event-to-dispatch latency, and recovery after outages.
Test missing telemetry, contradictory incident reports, unexpected closures, and infeasible schedules deliberately. Aggregate averages can conceal weak performance in precisely the conditions that justify dynamic routing.
Make the decision traceable before scaling
A dispatcher should be able to understand why a route changed: the triggering event, affected commitments, expected benefit, and constraints preserved. This does not require exposing every model parameter. It requires an operational explanation supported by recorded input versions, model versions, and approval history.
The Global Industrial Intelligence Hub (GIIH) connects logistics and supply-chain analysis with mobility and wider industrial intelligence. That cross-sector perspective is useful when comparing routing technologies: traffic prediction, vehicle capability, delivery obligations, and regional requirements need to be assessed together rather than as isolated features.
Before expanding a deployment, request a documented event-to-decision trace and a controlled pilot with agreed acceptance thresholds. AI delivery optimization earns operational trust when it can show not only that a route changed, but that the change was feasible, timely, understood, and better than leaving the plan alone.
Next :NoneRecommended News
 Oct 21, 2026How AI delivery optimization adapts routes to real-time trafficDiscover how AI delivery optimization adapts routes to real-time traffic, protects delivery commitments, and balances fleet costs. Learn what to test before scaling.
 Oct 09, 2026When does same-day delivery make sense for retail orders?Last mile delivery for retail: discover when same-day delivery drives profitable growth, customer loyalty, and competitive advantage—and when it costs more than it delivers.
 Sep 21, 2026How to assess a carrier for reliable delivery across EuropeReliable delivery Europe starts with the right carrier. Learn how to assess lane performance, customs capability, tracking, claims, and contingency planning.
 Aug 01, 2026Last Mile Sourcing Guides in Singapore: How Buyers Compare Suppliers and CostsLast mile sourcing guides Singapore: compare suppliers beyond headline rates. Learn how buyers assess hidden costs, service reliability, compliance, and delivery fit before awarding volume.
 Jul 10, 2026Last Mile Delivery for Scheduled Routes: How to Cut Delays and Improve Stop EfficiencyLast mile delivery for scheduled routes: learn how to cut delays, improve stop efficiency, and boost on-time performance with practical route planning strategies.
![]() Jul 07, 2026How to Choose Mobility Components for Delivery Fleets Based on Route, Load, and MaintenanceMobility components for delivery fleets should match route demands, payload peaks, and maintenance capacity. Learn how to cut downtime, control lifecycle cost, and choose smarter fleet parts.
 Jul 05, 2026Ecommerce Logistics Optimization: How to Cut Split Shipments and Last-Mile CostsEcommerce logistics optimization strategies to reduce split shipments and last-mile costs. Learn data-driven ways to improve margins, delivery stability, and fulfillment efficiency.
 Jul 01, 2026Ecommerce Logistics in North America: Cost Factors in Last-Mile FulfillmentEcommerce logistics North America costs rise fast in last-mile fulfillment. Learn the key drivers behind delivery, returns, and vendor pricing to protect margins and make smarter logistics decisions.
 Jun 20, 2026How to Choose Portable Power Banks for Travel, Field Work, and Emergency BackupPortable power banks buying guide for travel, field work, and emergency backup. Compare capacity, charging speed, safety, and portability to choose the right model with confidence.
![]() Jun 09, 2026Dash Cams for Fleet Safety: Key Features, Storage Options, and Installation MistakesDash cams for fleet safety: compare must-have features, storage options, and common installation mistakes to reduce claims, improve driver oversight, and choose the right setup faster.
 May 04, 2026Logistics management costs rise fast with urgent replenishmentLogistics management costs surge with urgent replenishment across aftermarket, industrial parts, and EV components. Learn how procurement, inventory control, and supply chain planning cut hidden costs.
 Oct 19, 2026Ecommerce delivery costs rise when address data goes wrongEcommerce delivery costs rise fast when address data fails. Learn logistics solutions for car spare parts and auto parts sellers to improve inventory control, inventory management, reliable delivery, and fast shipping.
 Oct 18, 2026Reliable delivery depends less on speed than on consistencyCar spare parts and auto parts delivery depends on inventory control, logistics management, and reliable delivery—not just fast shipping. Discover smarter logistics solutions.
 Oct 17, 2026Fast shipping is not always faster once returns are countedCar spare parts and auto parts need more than fast shipping. Discover how inventory control, logistics management, reliable delivery, and smarter logistics solutions improve ecommerce delivery.